
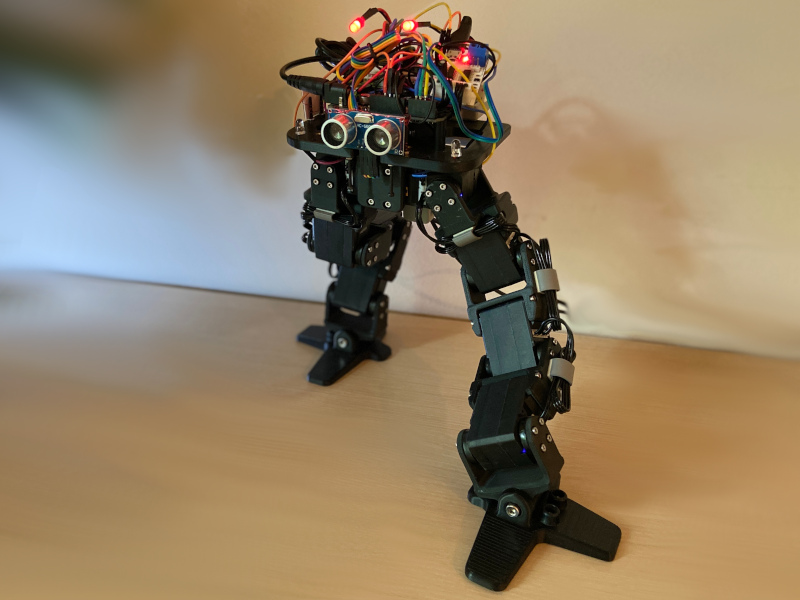
Show HN: 3D-printed bipedal robot with 8-servo limit to teach robotics
Original Text
I wanted to share a 10-DOF bipedal robot with open CAD files that I built. In my opinion, it is a nice platform for studying robotics. The machine can walk, sit, stand up after falls, kick, turn, and so on. Many of its movements were completely unexpected discoveries for me.
Some specs: 8 LX-16A servos, 2 free joints, a Raspberry Pi or Arduino SoC. What was hard about the build? The 8-servo limitation and initial gait implementations.
CAD: all custom-designed STEP+STL parts: https://grabcad.com/library/nix-robot-1
Code: I created an open-source Arduino library specifically for the LX-16A servos: https://docs.arduino.cc/libraries/lx16a-bus/ The core libraries are open, but gait sequences are detailed in my book (more on that below).
Demo with all moves developed so far: https://www.youtube.com/watch?v=Y30iI4bZyvg
Later on, I published a book for folks who want an absolutely precise guide on building it: https://nixrobot.pages.dev
Happy to answer your questions!
Comments (0 of ) ⌛