
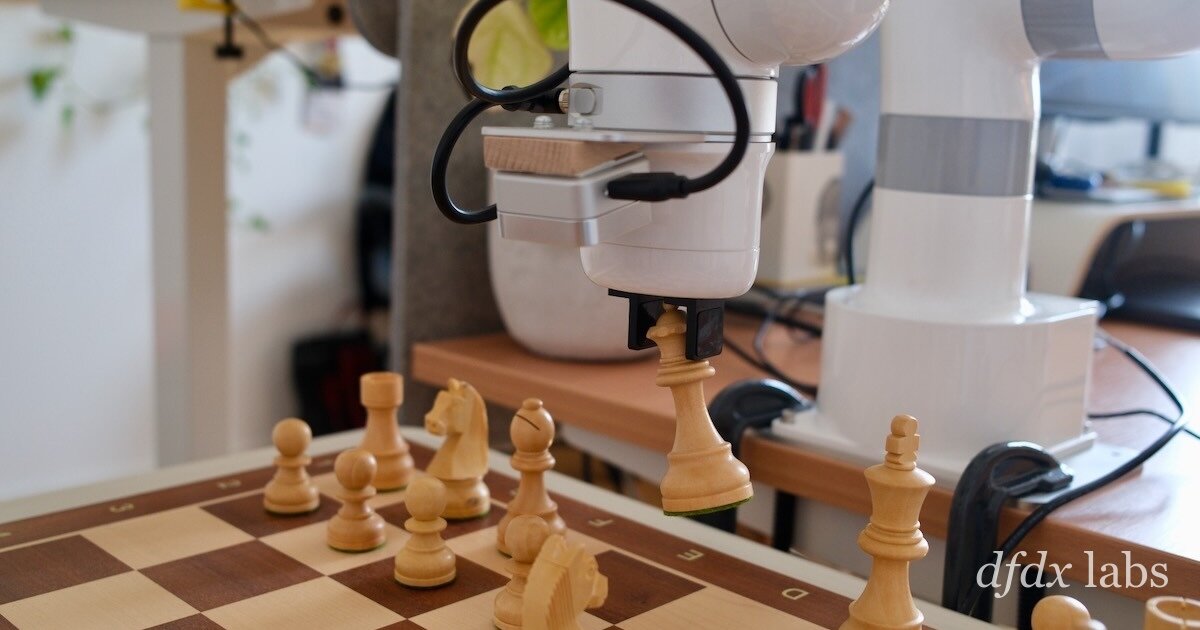
Building a robotics research setup that lives next to my desk
The first note in an independent robotics research project: a complete tabletop manipulation setup—industrial arm, two cameras, teleoperation, and a software stack built from scratch—for under €5,000.
Summary not yet generated for this article.
Original Text
Quick framing, since the post is long: I did robotic manipulation research at OpenAI from 2017–2020, and the tabletop setup back then cost roughly 10x this one and took a team to run. This project is me testing whether a single person can now do meaningful work on the same class of problems: starting with physical and software setup.
A few decisions I'm least settled on, and would love some pushback/feedback on:
- single arm vs. bimanual (I went single for cost/space, knowing it rules out things like folding cloth)
- not calibrating camera extrinsics/intrinsics for now
- RGB vs. RGB-D for from-scratch policies (ACT / Diffusion Policy)
And one I'm more confident about but expect disagreement on: not building on ROS 2 / LeRobot, and writing my own stack instead. Happy to get into the reasoning.
Comments (57 of ) ⌛